Home
> Products > Doppler Velocity Log (DVL) Series
Doppler Velocity Log (DVL) Series
High‑precision underwater velocity & altitude navigation sensors for AUV, ROV and USV in GPS‑denied subsea environments
Our full‑range DVL portfolio includes phased‑array split‑type DVL, piston‑type Janus‑configuration DVL, 5‑beam velocity‑altitude meter and compact anti‑current hover DVL. Frequency covers 150 kHz / 300 kHz / 600 kHz / 1000 kHz, supporting different altitude, depth‑rating, accuracy and integration requirements for coastal, offshore and deep‑sea missions.
Core Technical Advantages
✅ Phased‑array DVL:Electronic beam‑steering;lower minimum blanking zone;strong anti‑interference;multi‑beam redundancy;dry‑wet separated transducer & electronics design,easy vehicle integration
✅ Piston‑type Janus DVL:Proven 4‑beam mechanical array;two accuracy grades(export‑controlled / license‑free);multi‑interfaces Ethernet / RS422;optional ADCP current‑profiling function
✅ VAM‑600K 5‑beam sensor:Extra center depth‑sounding beam;combined velocity‑altitude measurement for towed bodies & UUVs
✅ Hover‑H1000 compact DVL:Ultra‑small diameter, ultra‑low blind zone(<5 cm); low‑power; dedicated for anti‑current station‑keeping on miniature ROV / AUV
Four Product Series Group
Series Ⅰ: DVL Phased Array Series (Split Type)
Modular split‑design phased‑array Doppler Velocity Log. Dry‑wet separation, compact transducer, optimized for modern AUV/ROV integration. Frequency options: 150 kHz /300 kHz /600 kHz, max bottom‑track altitude up to 500 m, depth rating optional up to 6000 m。

DVL-600K-Phased
600 kHz;Altitude:1‑110 m;Velocity Accuracy ±0.2% ±1 mm/s;ideal for compact AUV/inspection ROV

DVL-300K-Phased
300 kHz;Max altitude 200 m;Accuracy ±0.3% ±1 mm/s;suitable for deep‑sea long‑range cruise AUV & work‑class ROV

DVL-150K-Phased
150 kHz;Max bottom‑track altitude up to 500 m;two accuracy variants I / II;for ultra‑long‑range deep‑water deployment
Series Ⅱ:DVL Piston‑type Series (Janus 4‑beam)
Classic piston‑shaped Janus 4‑beam mechanical‑array DVL. Two accuracy grades available(export‑controlled / license‑free). Support optional ADCP current‑profile observation for vehicle navigation & mooring buoy application.
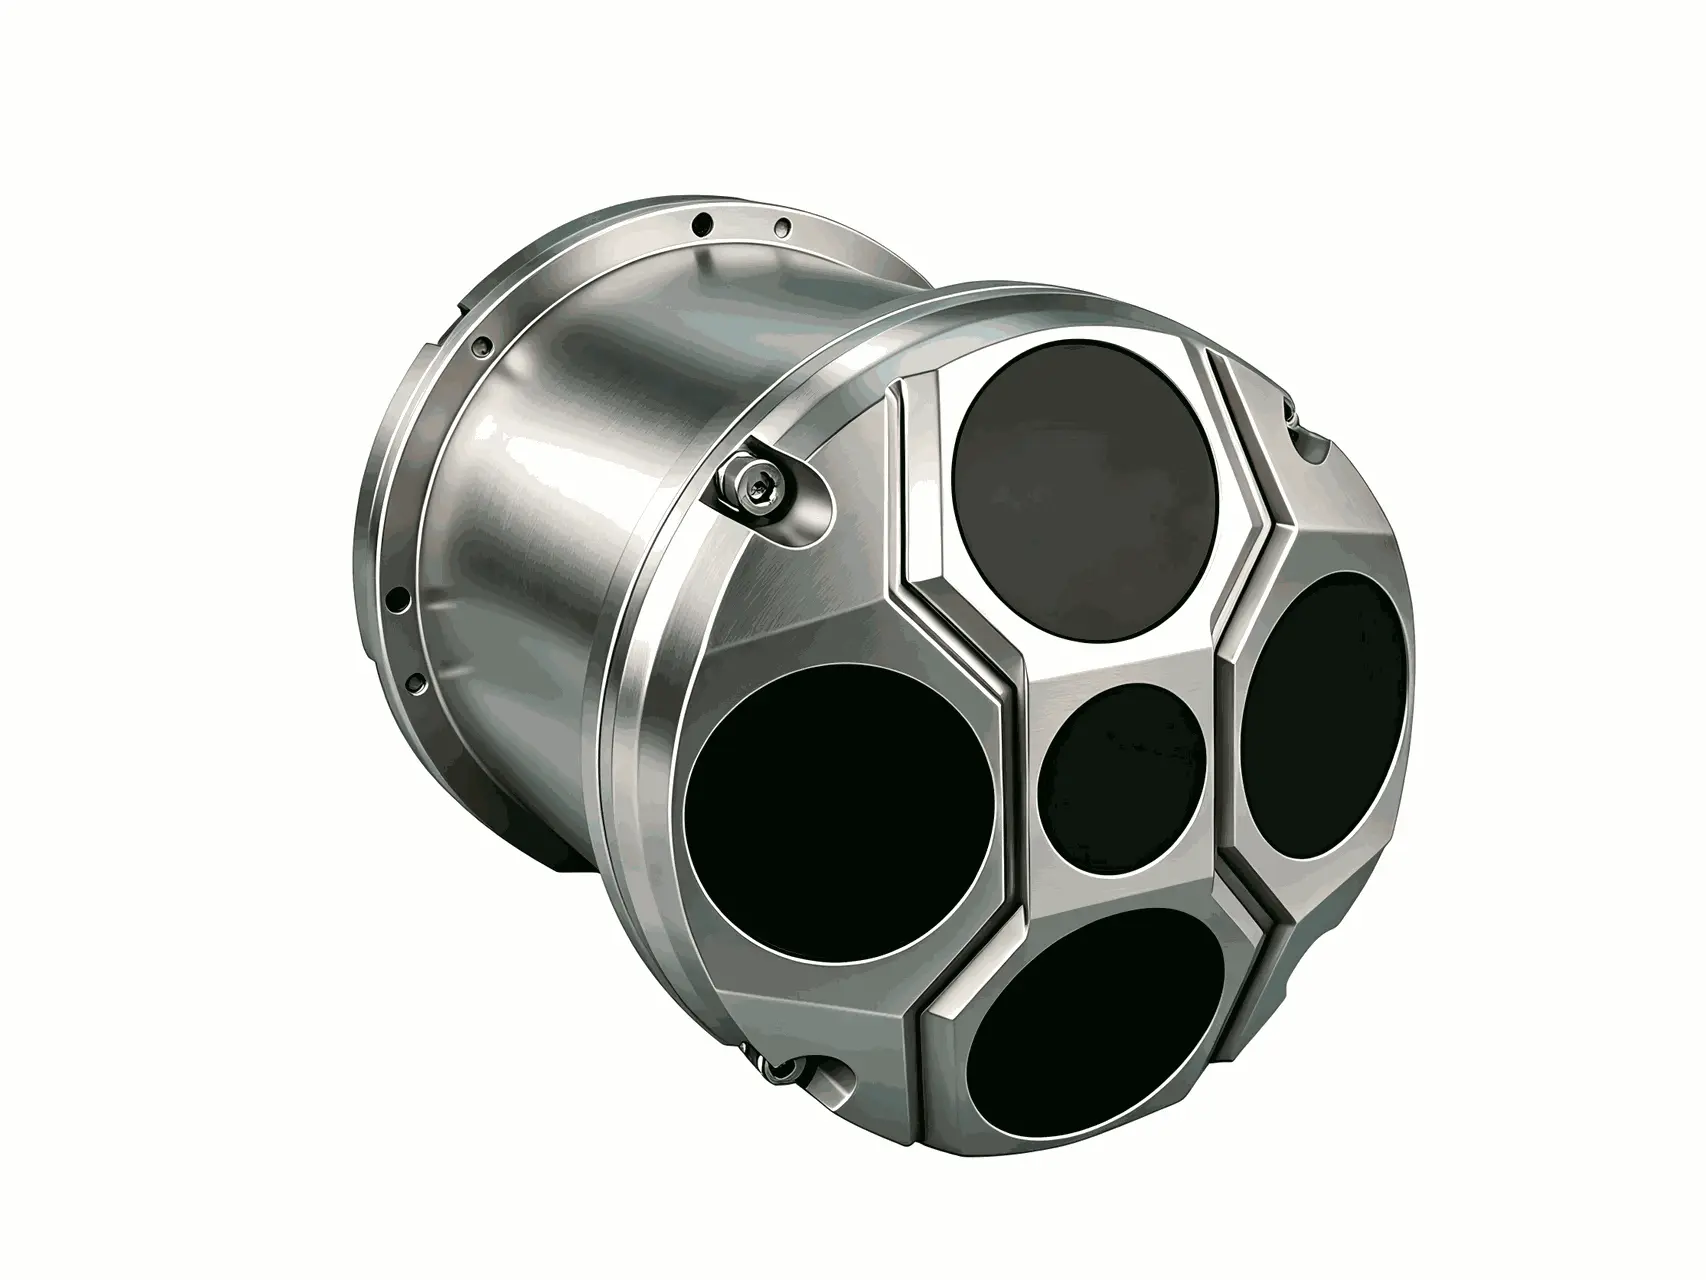
DVL-600K Piston-type
600 kHz;Min altitude 0.5 m;Max altitude 100 m;Excellent near‑seabed performance;titanium housing;average power 8 W
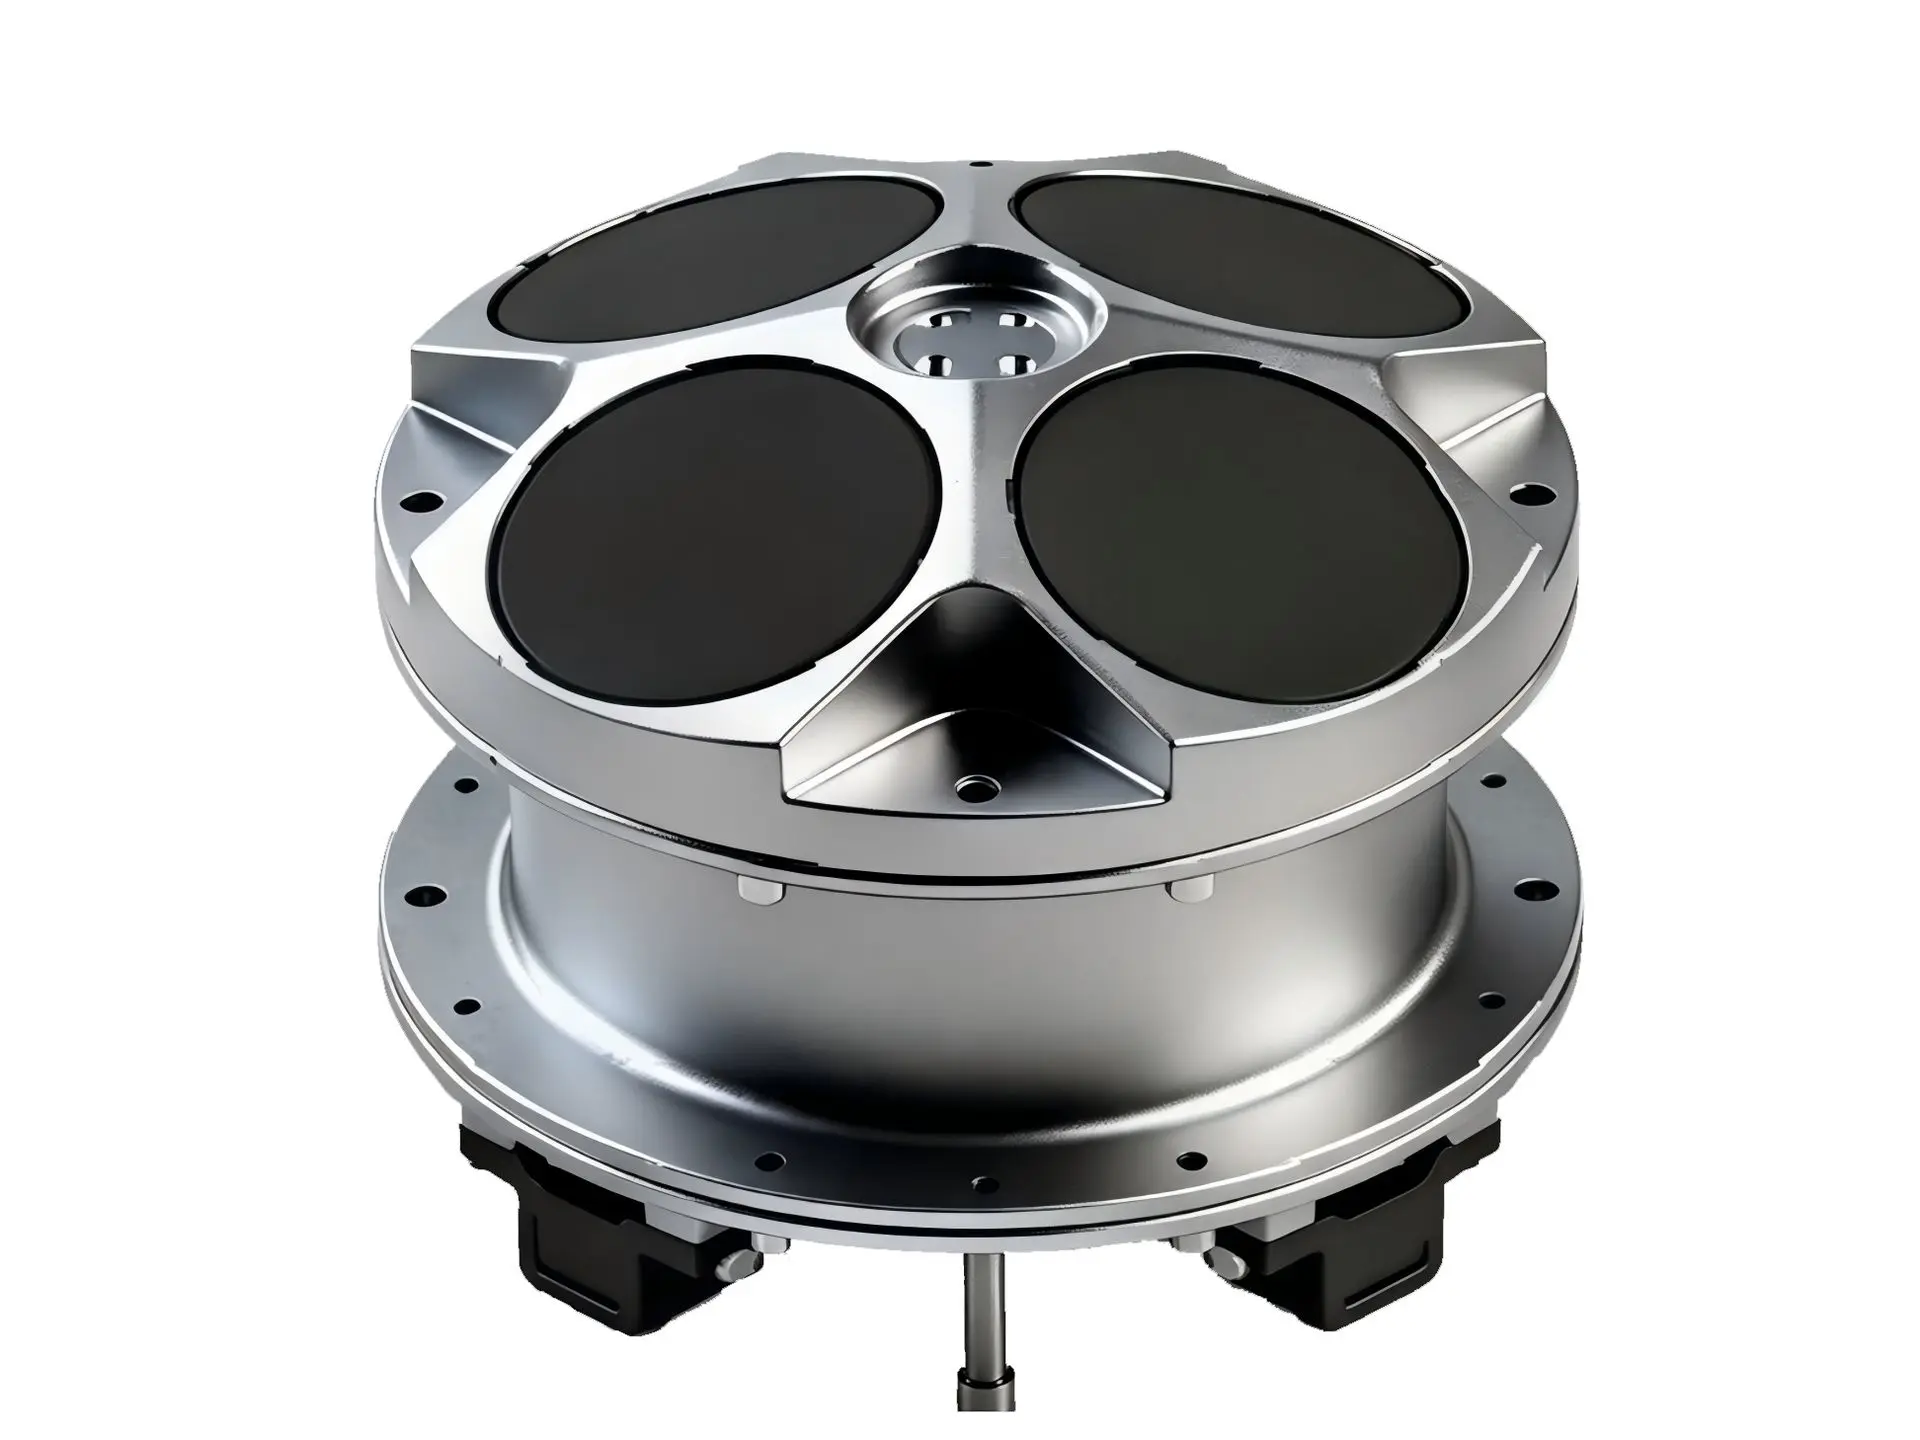
DVL-300K Piston-type
300 kHz;Max altitude 250 m;Min altitude 1 m;good for high stand‑off altitude long‑range AUV cruise
Series Ⅲ:Acoustic Velocity‑Altitude Meter Series
VAM‑600K 5‑beam integrated velocity‑altitude sensor, adds an optional 400 kHz center depth‑sounding beam. Target for UUV, towed‑array, seabed‑following control system.
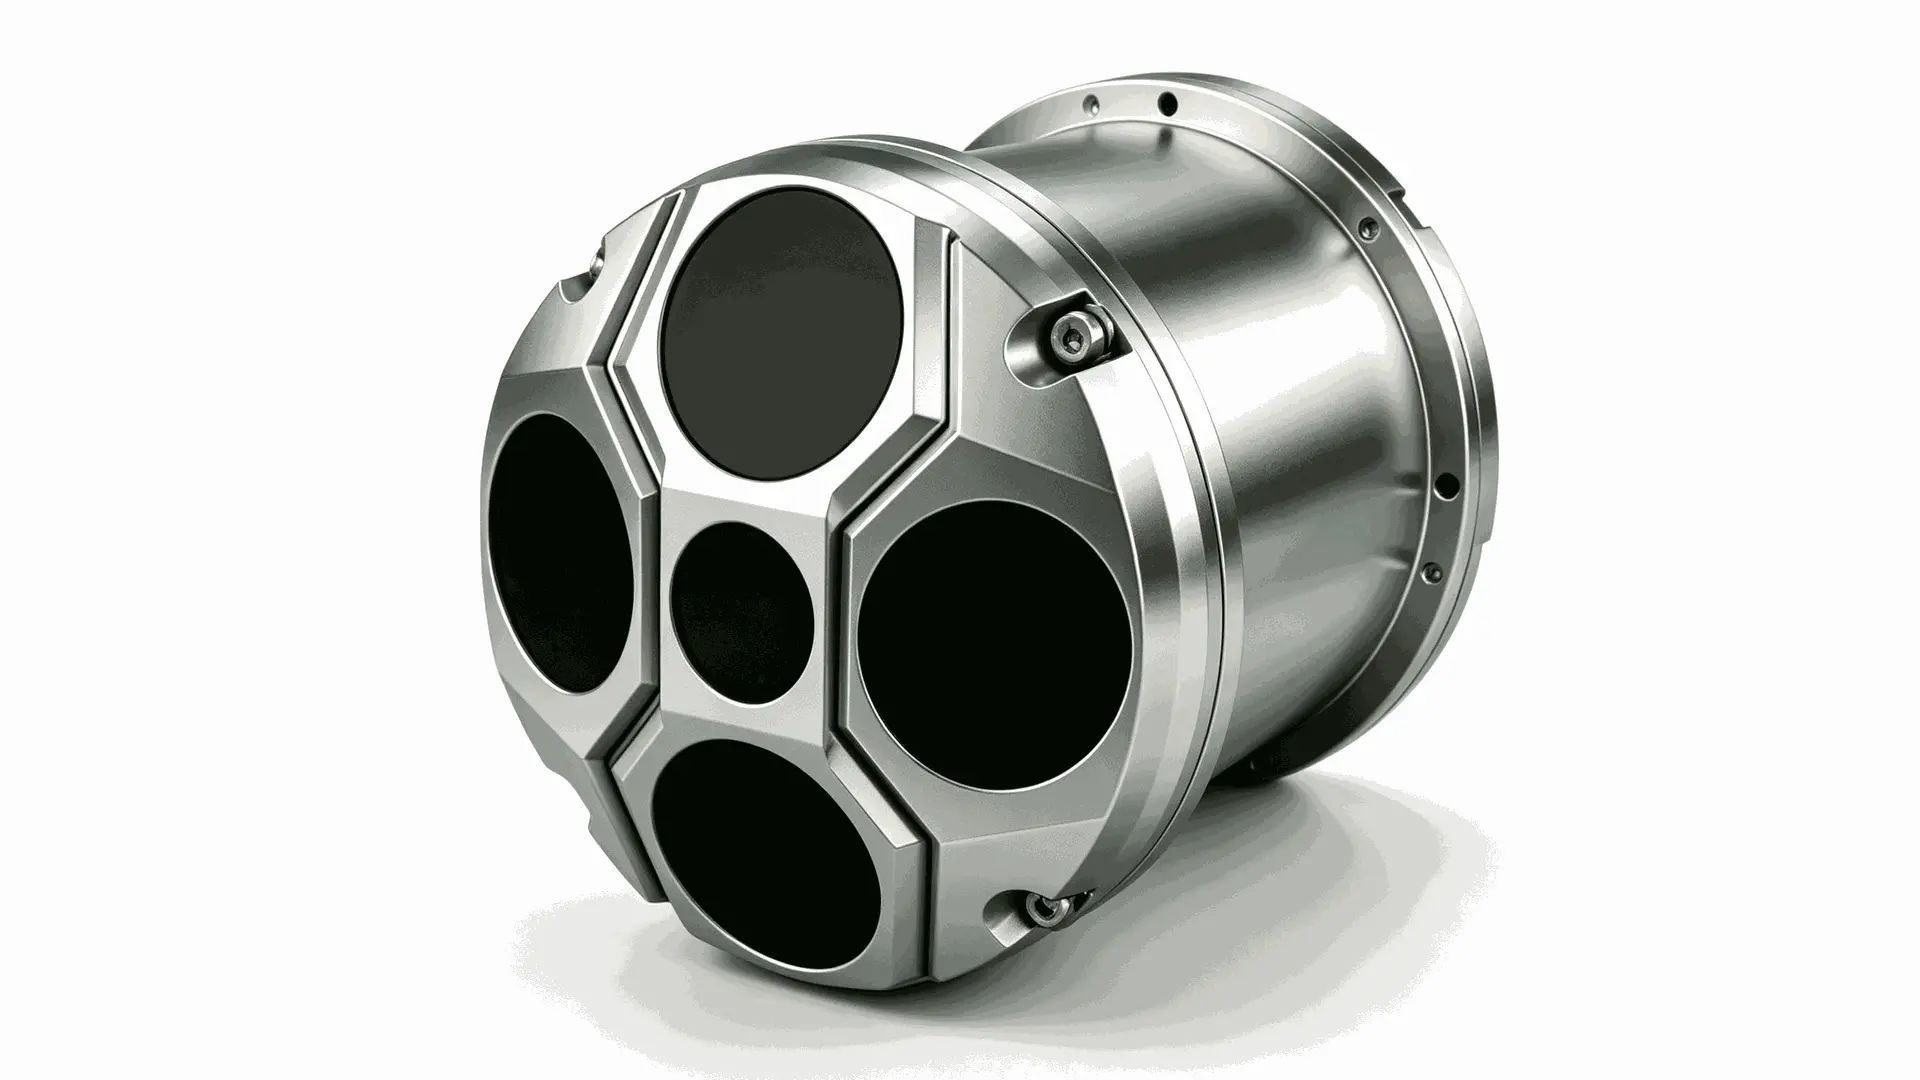
VAM-600K
600 kHz,5‑beam configuration;Min altitude 0.5 m;Max altitude 100 m;multi‑interfaces Ethernet/RS422;dual accuracy grades
Series Ⅳ:Underwater Anti‑Current Hover Navigation Sensor Series
Ultra‑compact low‑power DVL for small‑size ROV/AUV station‑keeping. Extremely small acoustic blind zone for very close‑to‑seabed inspection tasks.

DVL-Hover-H1000
1000 kHz;Blind‑zone<5 cm;max altitude typical 45 m;power ≤5 W;Φ92 mm compact diameter; focus on bottom‑track anti‑current hover control
Specifications
Note: Some models offer two accuracy grades: export‑controlled high‑accuracy version and license‑free general‑purpose version, please specify during inquiry.
Application Scenarios
- Autonomous Underwater Vehicles(AUVs): compact / large‑diameter AUV long‑range cruise & near‑bottom survey
- Remotely Operated Vehicles(ROVs): inspection‑class & work‑class ROV station‑keeping & subsea intervention
- Uncrewed Surface Vessels(USVs): ground‑speed measurement & drift compensation when GPS degraded
- Underwater tow‑body & towed‑array mapping survey
- Oceanographic mooring & buoy: current‑profile observation(ADCP‑enabled models)
- Off‑shore engineering, pipeline inspection, sub‑sea infrastructure monitoring
How does DVL work?
A Doppler Velocity Log (DVL) calculates 3‑dimensional platform velocity and altitude above seabed based on acoustic Doppler effect. It transmits acoustic beams toward seabed, analyses echo frequency shift, outputs bottom‑track velocity. When bottom‑lock is lost, water‑track mode provides velocity relative to water column for dead‑reckoning navigation without satellite GPS signal。
Need technical consultation or quotation for DVL sensors?
Tell us your platform type(AUV/ROV/USV), working depth, expected altitude and accuracy requirements. Our engineering team will recommend suitable DVL solution for you. Our engineering team will recommend suitable DVL solution for you.
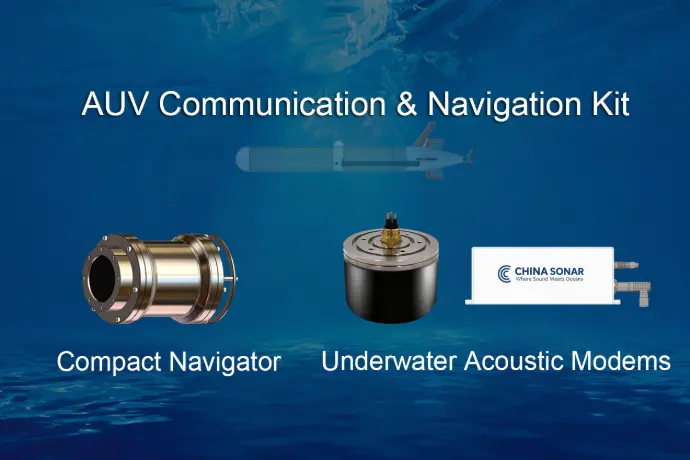
Supporting Solution:AUV Communication & Navigation Kit
Combined system:NAVS‑3000 Compact Navigator + UAC‑08160X Underwater Acoustic Modem
- NAVS‑3000:INS integrated navigation, fuse DVL velocity + depth data for real‑time high‑precision positioning
- UAC‑08160X:Multi‑band long‑range underwater acoustic communication
Link:Discover more about AUV navigation‑communication kit