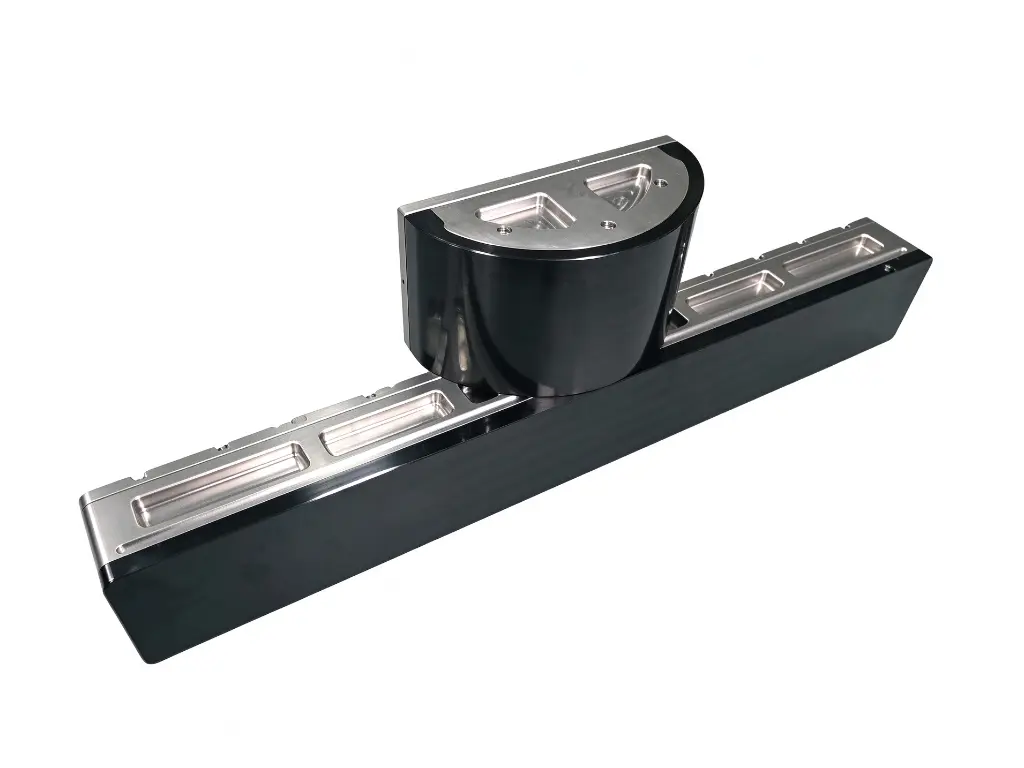
UAC-FLS100 Multibeam Forward Looking Sonar
500m Long Detection Range | Collision Avoidance;
100kHz Imaging Sonar for medium and large underwater vehicles
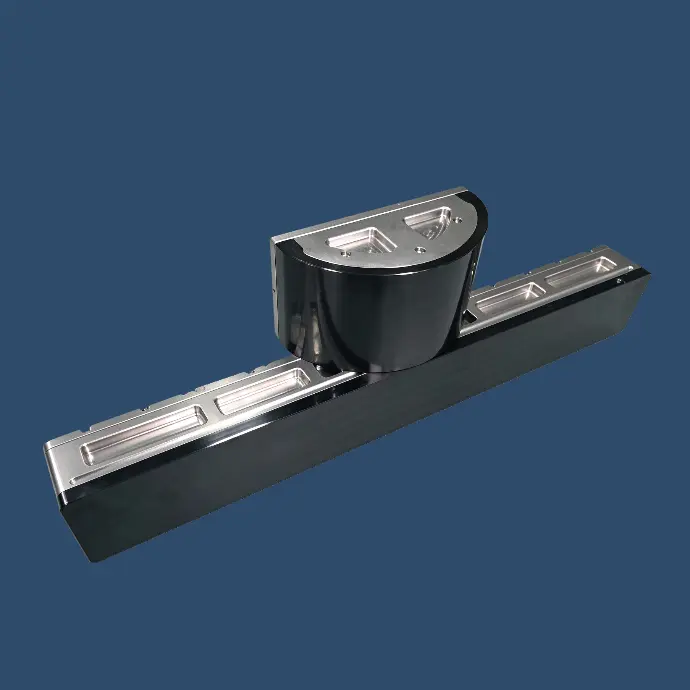
The UAC-FLS100 Imaging Sonar adopts multibeam imaging technology to generate acoustic images of suspended underwater targets and obstacles ahead of the sonar. All components are domestically manufactured, with fully self-controllable software and hardware. It meets the navigation assurance and target detection requirements of medium and large underwater vehicles.
| Operating Frequency: Center frequency: 100 kHz |
| Angular Resolution: 0.96° |
| Horizontal Field of View: 105° |
| Vertical Field of View: 26° in imaging mode, 7° in collision avoidance mode (adjustable) |
| Maximum Detection Range: ≥500 m (for -15dB target under favorable hydrological conditions) |
| Range Resolution: 3.75 cm |
| Communication interface: 100M / 1G adaptive Ethernet |
| Power Supply / Power Consumption: 18~36 VDC, typical power consumption: 22 W |
| Maximum Operating Depth: 600 m (customizable upon request) |
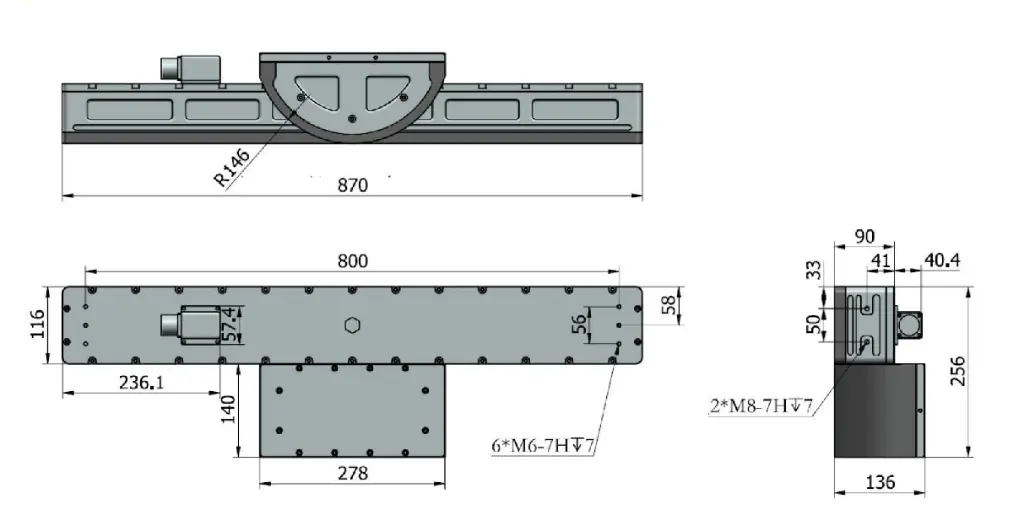
| Weight: 30 kg (Titanium Alloy TC4) |
| Environmental Adaptability: Operating temperature: -10℃ ~ 50℃; Storage temperature: -40℃ ~ 70℃ |
| Software Development: Control & display software and SDK available, supporting secondary development |
Key Features
- Long Detection Range
Up to 500m detection range for -15dB target under good hydrological conditions, supports long-distance ahead perception for subsea vehicles. - Dual Working Modes (Imaging + Collision Avoidance)
Switchable vertical FOV: 26° for detailed imaging, 7° for high-speed collision avoidance. Adjustable mode for different mission priorities. - Fully Independent & Domestic Supply Chain
Software & firmware fully self-developed, Stable technical support. - Open SDK & Easy Integration
Comes with display & control software and SDK, supports secondary development for custom AUV/USV control systems.
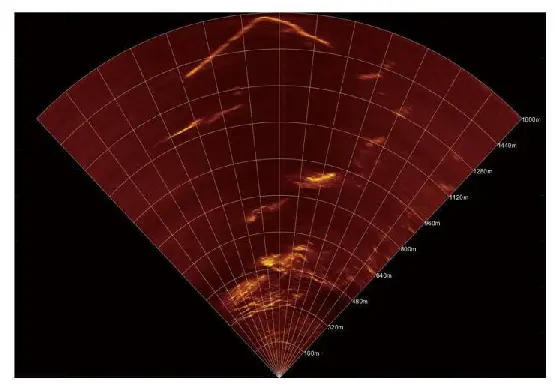
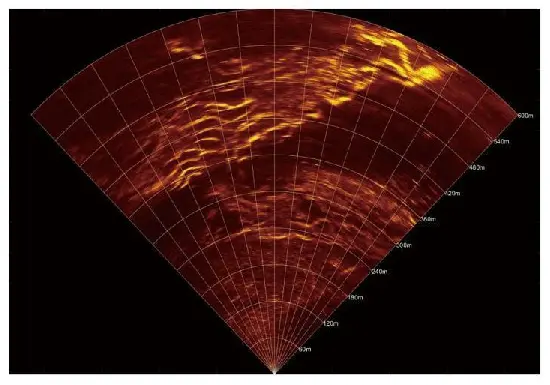
Dual-Frequency Demo Video & Images
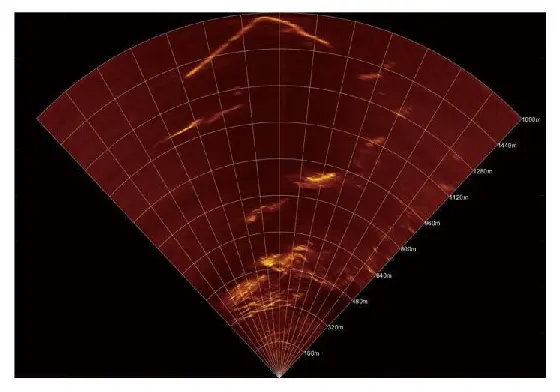
Dam-Imaging-at-1300-m-Range
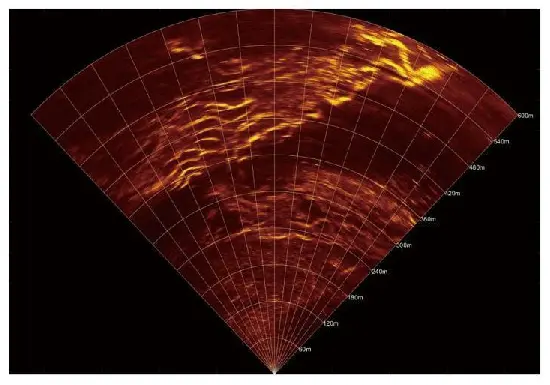
Open-Water-Imaging
Applications
- AUV / Medium-large underwater vehicle navigation safety & obstacle avoidance
- Subsea infrastructure inspection, dam & levee survey
- Underwater suspended object search & target detection
- Offshore engineering, inland river & channel underwater investigation
FAQ
Yes, SDK and Ethernet protocol document are supplied for secondary development and system integration.
Custom depth rating is available on request.
It supports imaging mode (26° vertical FOV for detailed acoustic imaging) and collision avoidance mode (7° vertical FOV for obstacle alert). The vertical field of view is adjustable.
≥500m for -15dB target under favorable hydrological conditions. The actual detection distance will be affected by water quality, ambient noise and target strength.
It works on 18~36 VDC power supply with typical power consumption of 22W, and uses 100M / 1G adaptive Ethernet for data communication.