Home > Compact Navigator > NAVS-P600K
NAVS-P600K-3000M
Compact Navigator
Surface & Underwater Navigation Position System
High-performance INS/DVL integrated navigation system for AUV, ROV and marine engineering vessels
NAVS‑P600K‑3000M is an all‑in‑one compact navigation unit with autonomous dynamic north‑seeking capability for fully autonomous, all‑weather underwater navigation. It adopts a dedicated Kalman filter to deeply fuse INS, DVL, USBL and GNSS data, delivering high precision and stable navigation outputs of real‑time heading, attitude, velocity and position for deep‑sea moving underwater carriers. Featuring small size, low power consumption and cost advantages, it is ideal for deep‑diving AUV, work‑class ROV and subsea marine engineering platforms.
VIEW SPECIFICATIONS DOWNLOAD DATASHEET
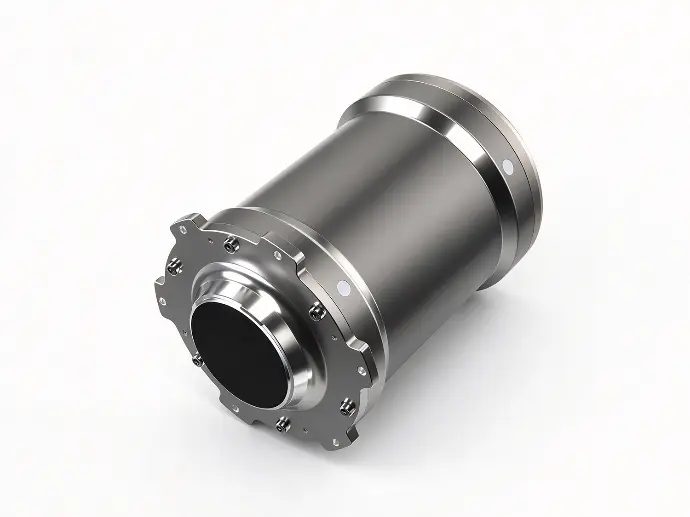
NAVS-P300K-3000M Navigation Position System
Key Features:
- Autonomous dynamic north‑seeking, underwater navigation capability, fully‑autonomous and all‑weather operational performance
- Compact all‑in‑one integrated design featuring low power consumption, small footprint and cost‑effective advantages
- Dedicated Kalman filter deeply fuses multi‑source data including INS, DVL, USBL and GNSS, delivering superior navigation accuracy and outstanding system stability
- Configurable data output rate ranging 1‑200 Hz, equipped with standard RS422/RS232 serial interfaces for seamless integration with third‑party underwater vehicle controllers
- Supports both static and dynamic alignment; custom gyroscope measurement range is available upon special project requests
Key Features
Specifications
Applications
Deep‑Water Marine Resource Exploration
Suitable for deep‑sea oil & gas field survey, subsea rig installation, deep‑water pipeline laying, and offshore deep‑sea infrastructure construction. Supports long‑duration continuous inspection and preventive maintenance for deep‑sea mooring systems and subsea pipelines in 3000 m water depth.
Deep‑Sea Underwater Engineering Operations
Supports integration with external aiding sensors including GNSS and USBL to boost long‑range positioning stability. Perfect for deep‑water search, rescue and salvage missions in open‑ocean environments, delivering reliable navigation solution for deep‑sea engineering tasks.
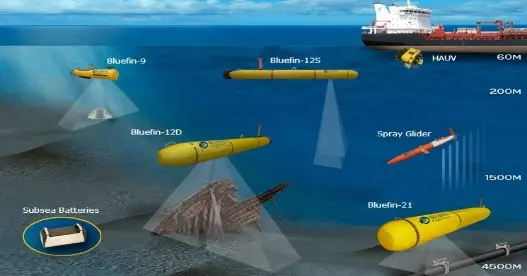
Deep‑Diving AUV / Work‑Class ROV / Large‑scale UUV Navigation
Optimized for deep‑water unmanned underwater platforms. Provides stable high‑accuracy navigation for deep‑sea seabed investigation, geological survey, long‑range route patrol and subsea data acquisition missions.
FAQ
The Q&A below refers to specifications of the Standard Version (License‑Required). For specifications of other versions, please refer to the technical datasheet or contact us.
The standard unit depth rating is 3000 m. Shallower or deeper customized pressure‑housing versions are available. Please send your project technical parameters for engineering evaluation.
Underwater positioning relies on INS+DVL dead‑reckoning when GNSS is unavailable. When DVL maintains stable bottom‑lock, position drift for PRO version can reach ≤0.5% D at vehicle speed ≤15 knots. GNSS fixes position when vehicle surfaces. External USBL can be connected as auxiliary underwater aiding source to reduce drift further.
Bottom‑track performance will degrade or drop out under heavy silt or dense aquatic weeds. If DVL bottom‑lock is lost, the navigation system will run on pure INS mode and position drift will increase significantly. We strongly recommend deploying USBL as backup auxiliary positioning for such complex water environments.
Standard hardware interfaces are RS422 / RS232 serial ports. Data output rate can be configured from 1 Hz up to 200 Hz. It supports standard marine navigation protocols and compatible with most mainstream ROV / AUV controllers. Custom protocol development service is available upon project request.
Default static alignment time ≤5 minutes; dynamic alignment ≤15 minutes. Please contact our engineering team for special fast‑alignment technical solutions if your mission requires quick start‑up.
Typical power consumption is less than 10 W. Low‑power design makes it well‑suited for battery‑operated deep‑diving AUV and work‑class ROV platforms.
Explore the ADCP Series
The China-Sonar ADCP Series covers the full spectrum of applications from shallow rivers to the deep ocean. With models including the ADCP-1200K, ADCP-600K, and ADCP-300K, the series is tailored for river discharge monitoring, coastal and offshore surveys, and deep-sea research & engineering.